2025# 01
National bronze — Delta Rover
RoboCup Mexican Open — Lunar Rover
DIV. 03
All-terrain platforms built to explore where there are no roads — or atmosphere.
COMPETES IN
OVERVIEW
The Lunar Rover category poses the planetary-exploration problem at student scale: loose terrain, craters, harsh lighting and collection tasks that demand a stable, precise platform.
Delta Rover is a semi-autonomous planetary-exploration platform built to navigate challenging off-road terrain while mapping, navigating and carrying out sample-collection tasks. A four-wheel differential drive with passive suspension on each wheel keeps it stable over uneven ground, while semi-autonomous navigation follows operator-defined waypoints on a 2D occupancy map built from an RP-LiDAR A1M8, with localization from an Extended Kalman Filter fusing wheel odometry and a 9-axis IMU, and path tracking through a pure-pursuit controller. An Orbbec depth camera complements the LiDAR with 3D reconstruction for obstacle perception and terrain analysis.
The rover also carries a custom 4-DOF manipulator for sample interaction, and a computer-vision pipeline detects and classifies colored rocks — simulating geological sample identification during planetary exploration. Embedded electronics, power distribution, motor control, sensing and communications were all designed and built in-house by the team.
GALLERY
SWIPE OR DRAG TO EXPLORE
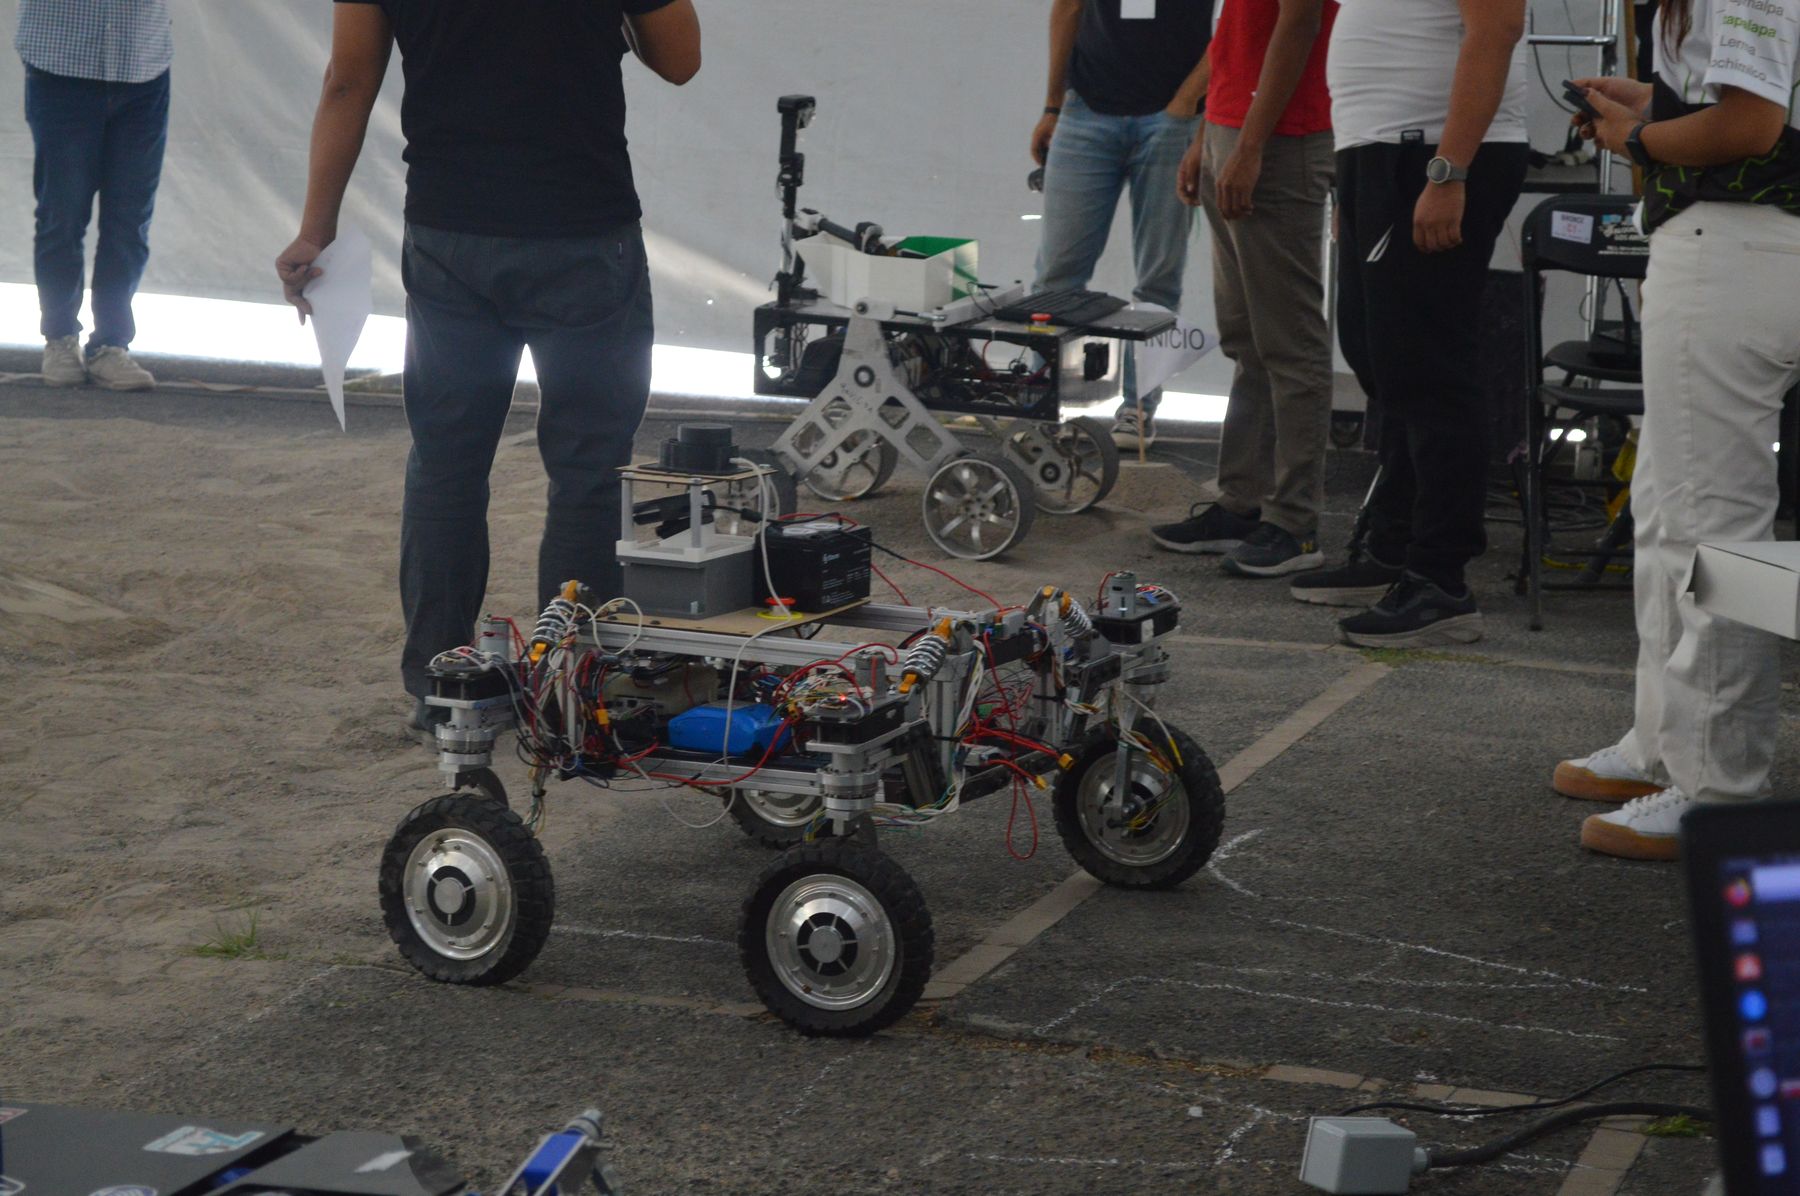 FIG. 01
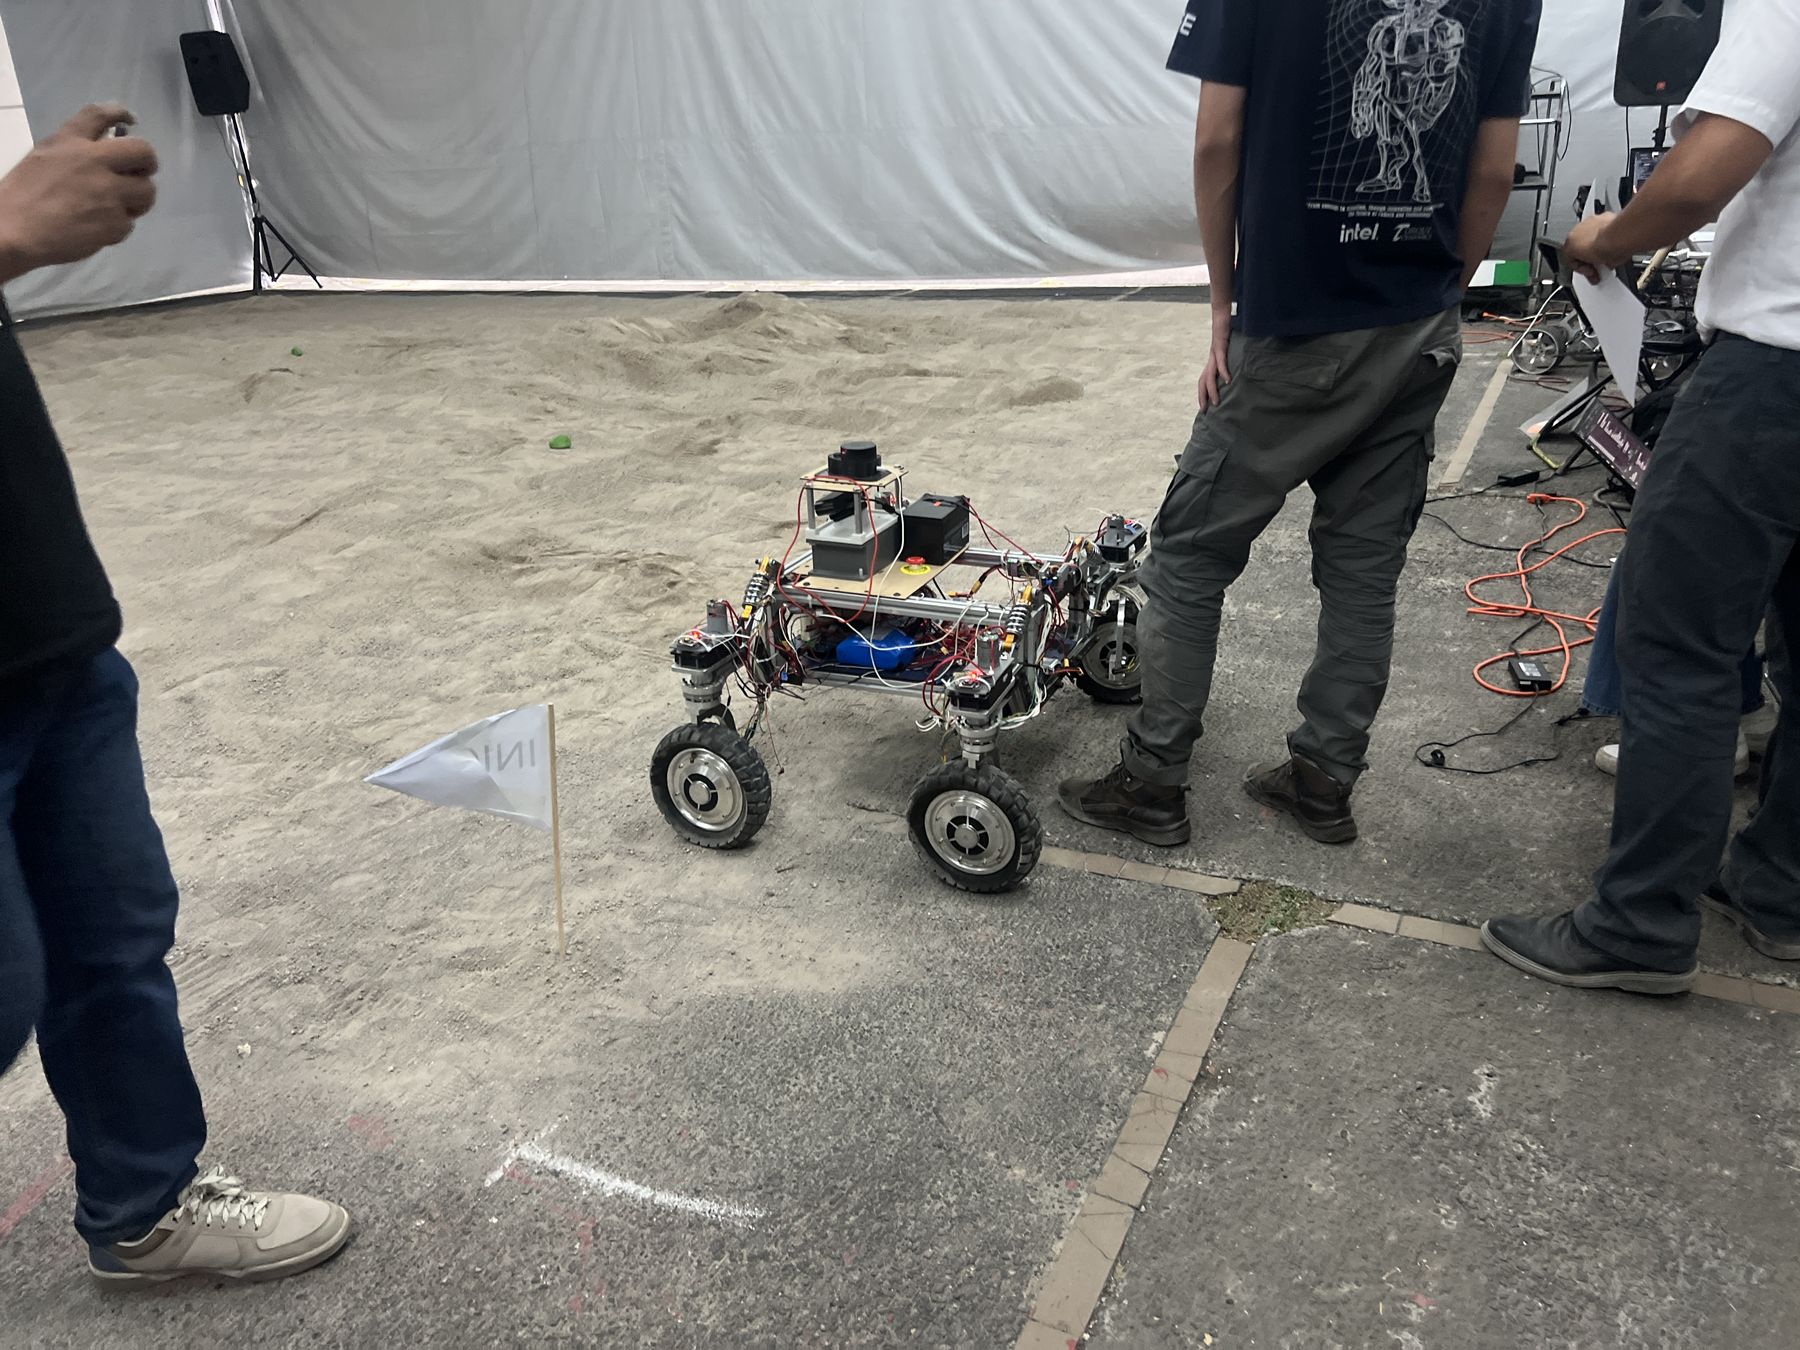 FIG. 02
RECORD STATUS
RoboCup Mexican Open — Lunar Rover